In the summer of 2020 I started building my own variometer – the instrument that tells a paraglider pilot whether they are climbing or sinking. The one I was flying with didn't work properly, so I decided to design my own.
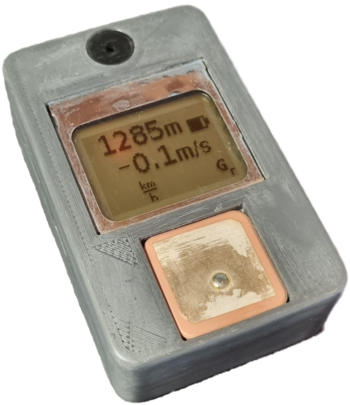
The variometer is built around an ESP8266 microcontroller and combines:
- GPS module – flight tracking and ground speed
- Barometer – altitude from air pressure
- Accelerometer – inertial measurements
- SD card reader – logging of the flight data
- Buzzer – acoustic feedback
- 4500 mAh LiPo with a battery management system
- An old Nokia display and a 3D-printed case
GPS and accelerometer data are fused with a Kalman filter to estimate position and velocity during the flight, according to the original project notes. The source and tuning are not published, so no quantitative flight-accuracy claim is made here.
The original description also mentions Bluetooth connectivity, but does not identify the interface module; the ESP8266 itself does not provide Bluetooth.
I also planned to use the accelerometer to record G-forces during flight – that feature is not implemented yet.