Testing & Validation
Building repeatable evidence from real mechatronic systems.
// robotics · control · embedded systems
Research Engineer / Project Manager Mechatronics
Based in Buchs SG, Switzerland
I build the hardware and software to find out whether a mechatronic system actually works.
2 patent applications filed 5 industrial prototypes at Hilti IEEE World Haptics WIP
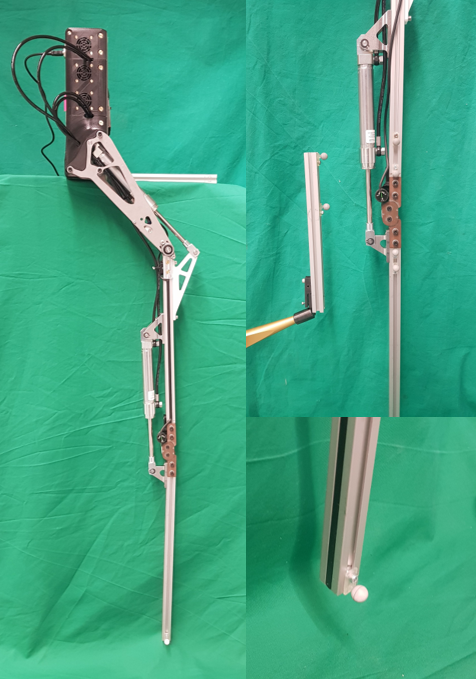 T-01 · 2023Hydraulic Exoskeleton
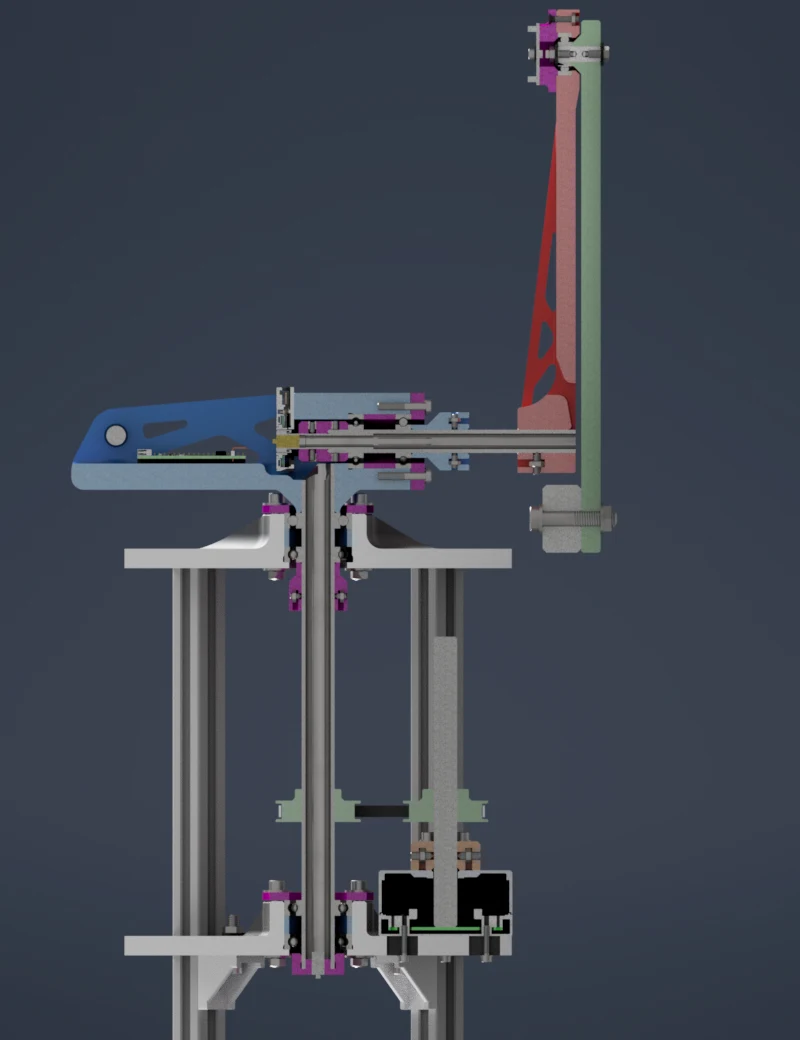 P-11Double PendulumIn progress
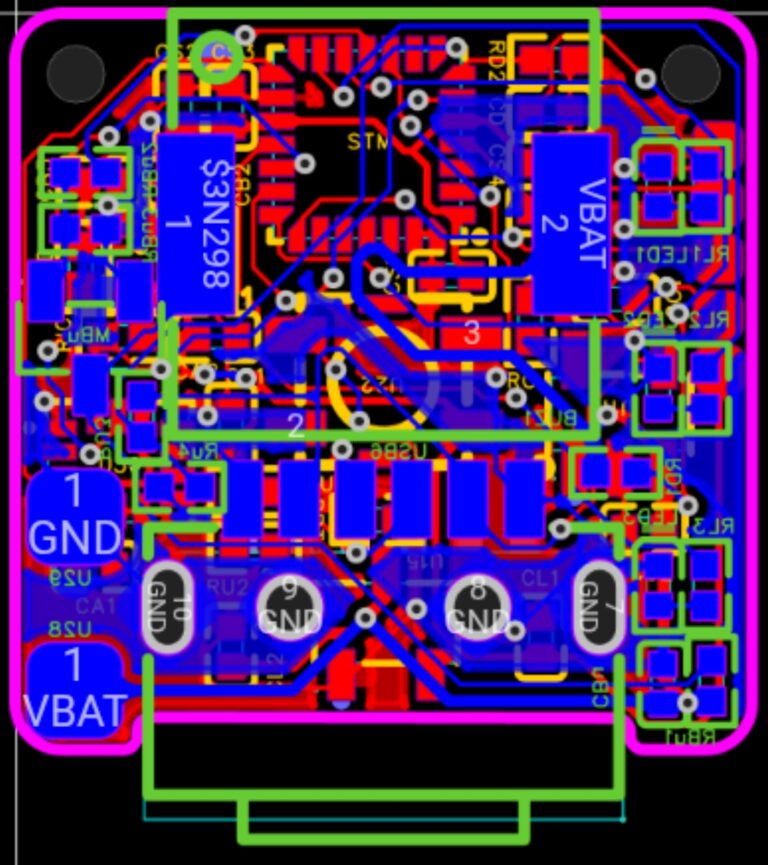 P-09 · 2026tiny vario
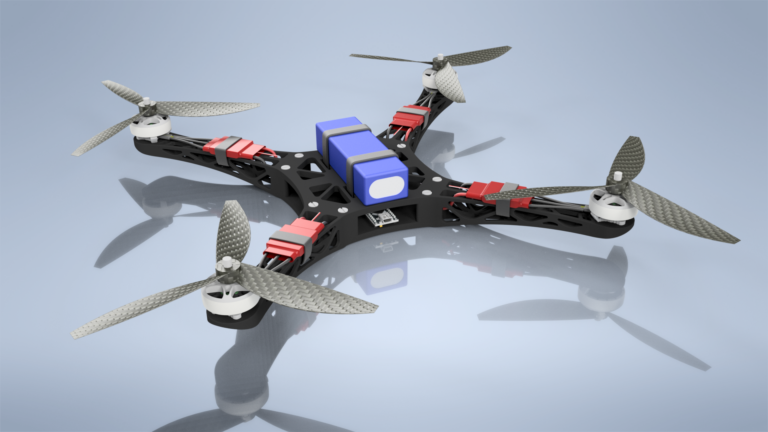 P-07 · 20243D Printed Drone
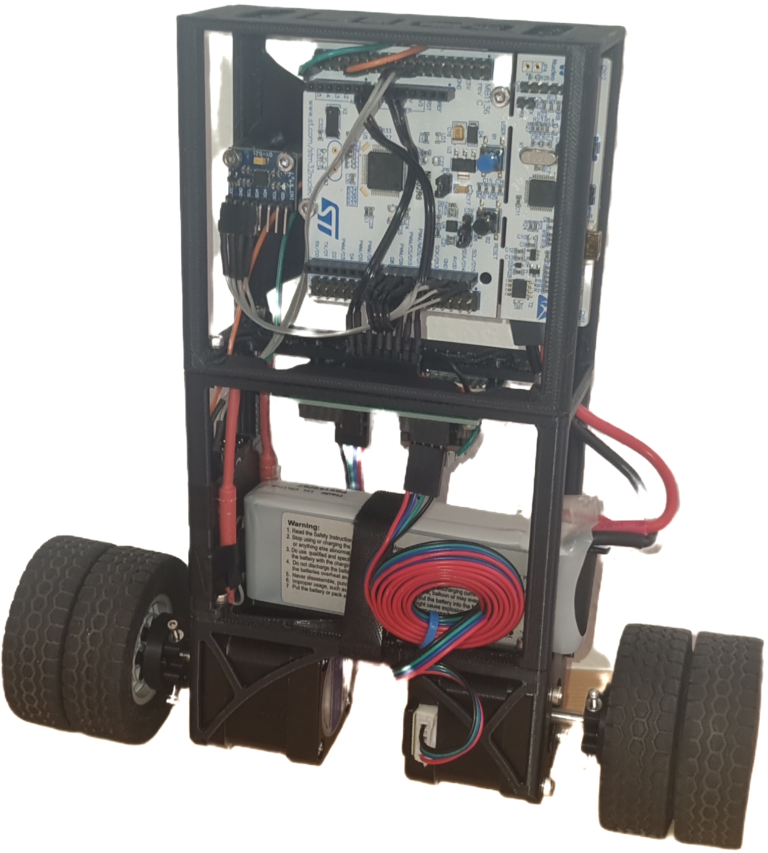 P-06 · 2023Balancing Robot
 P-03 · 2023Bilateral Teleoperation
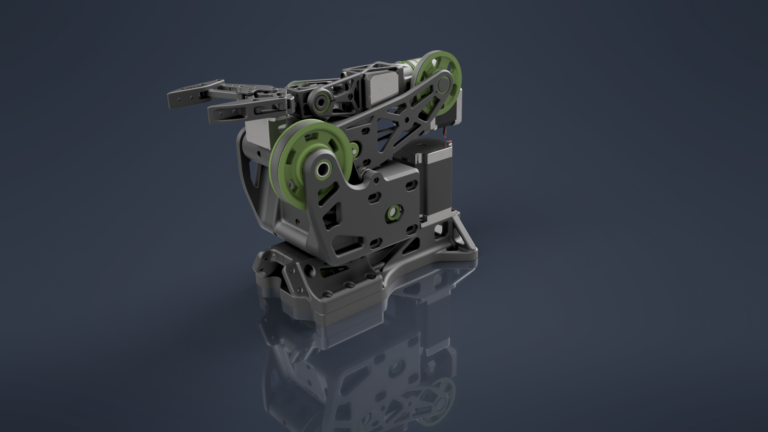 P-02 · 20226 DOF Robotic Arm
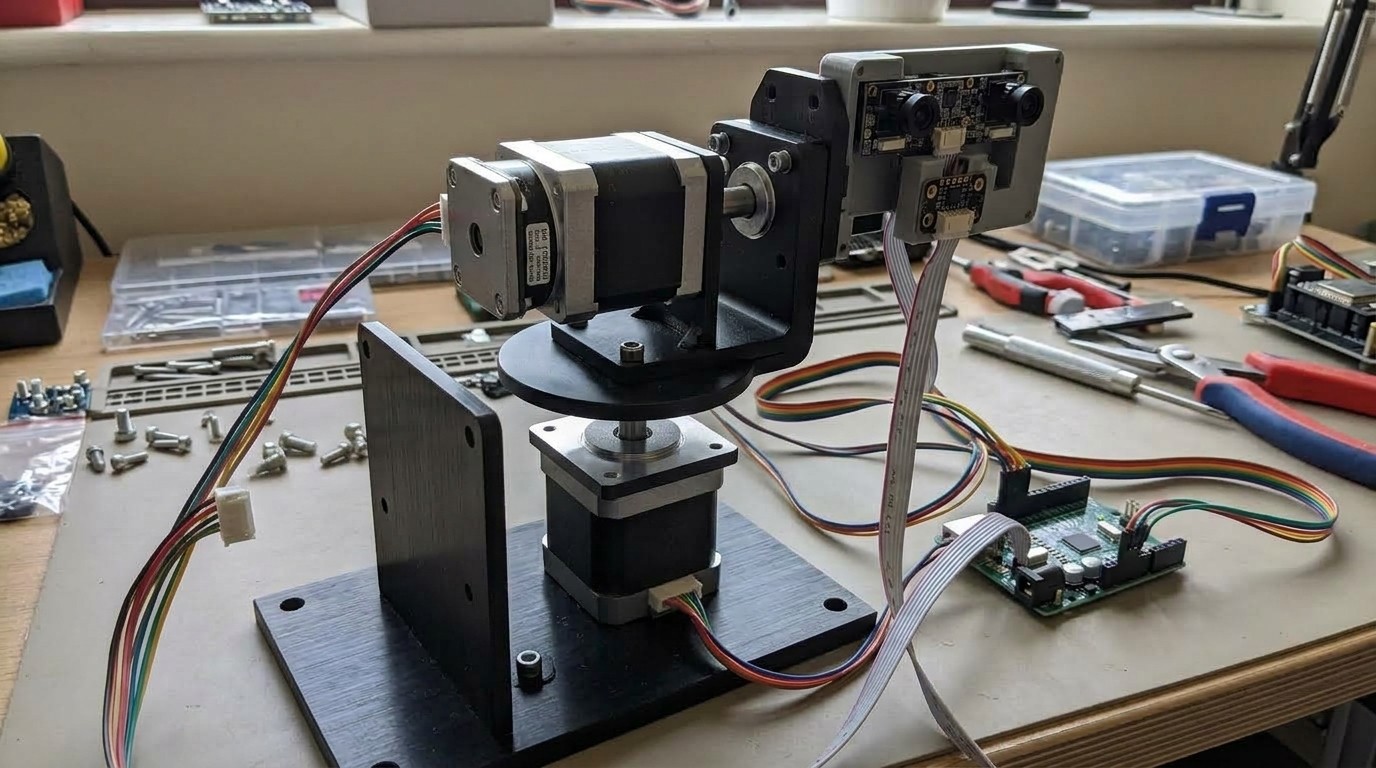 P-08Two-Axis Robotic Platform
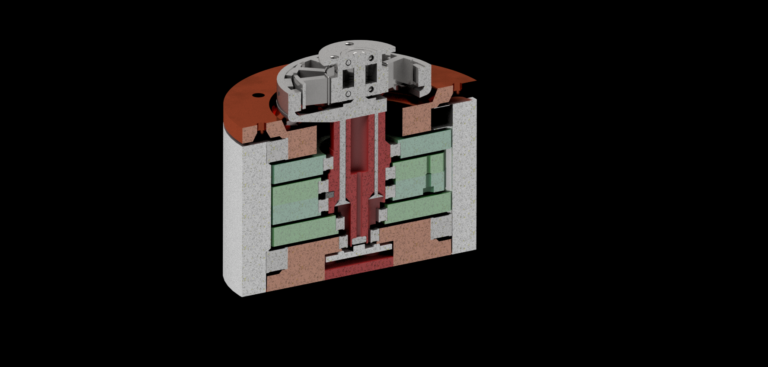 P-04 · 2023Torque-Sensing Actuator
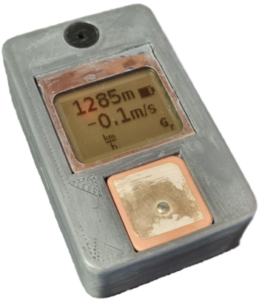 P-01 · 2020Variometer
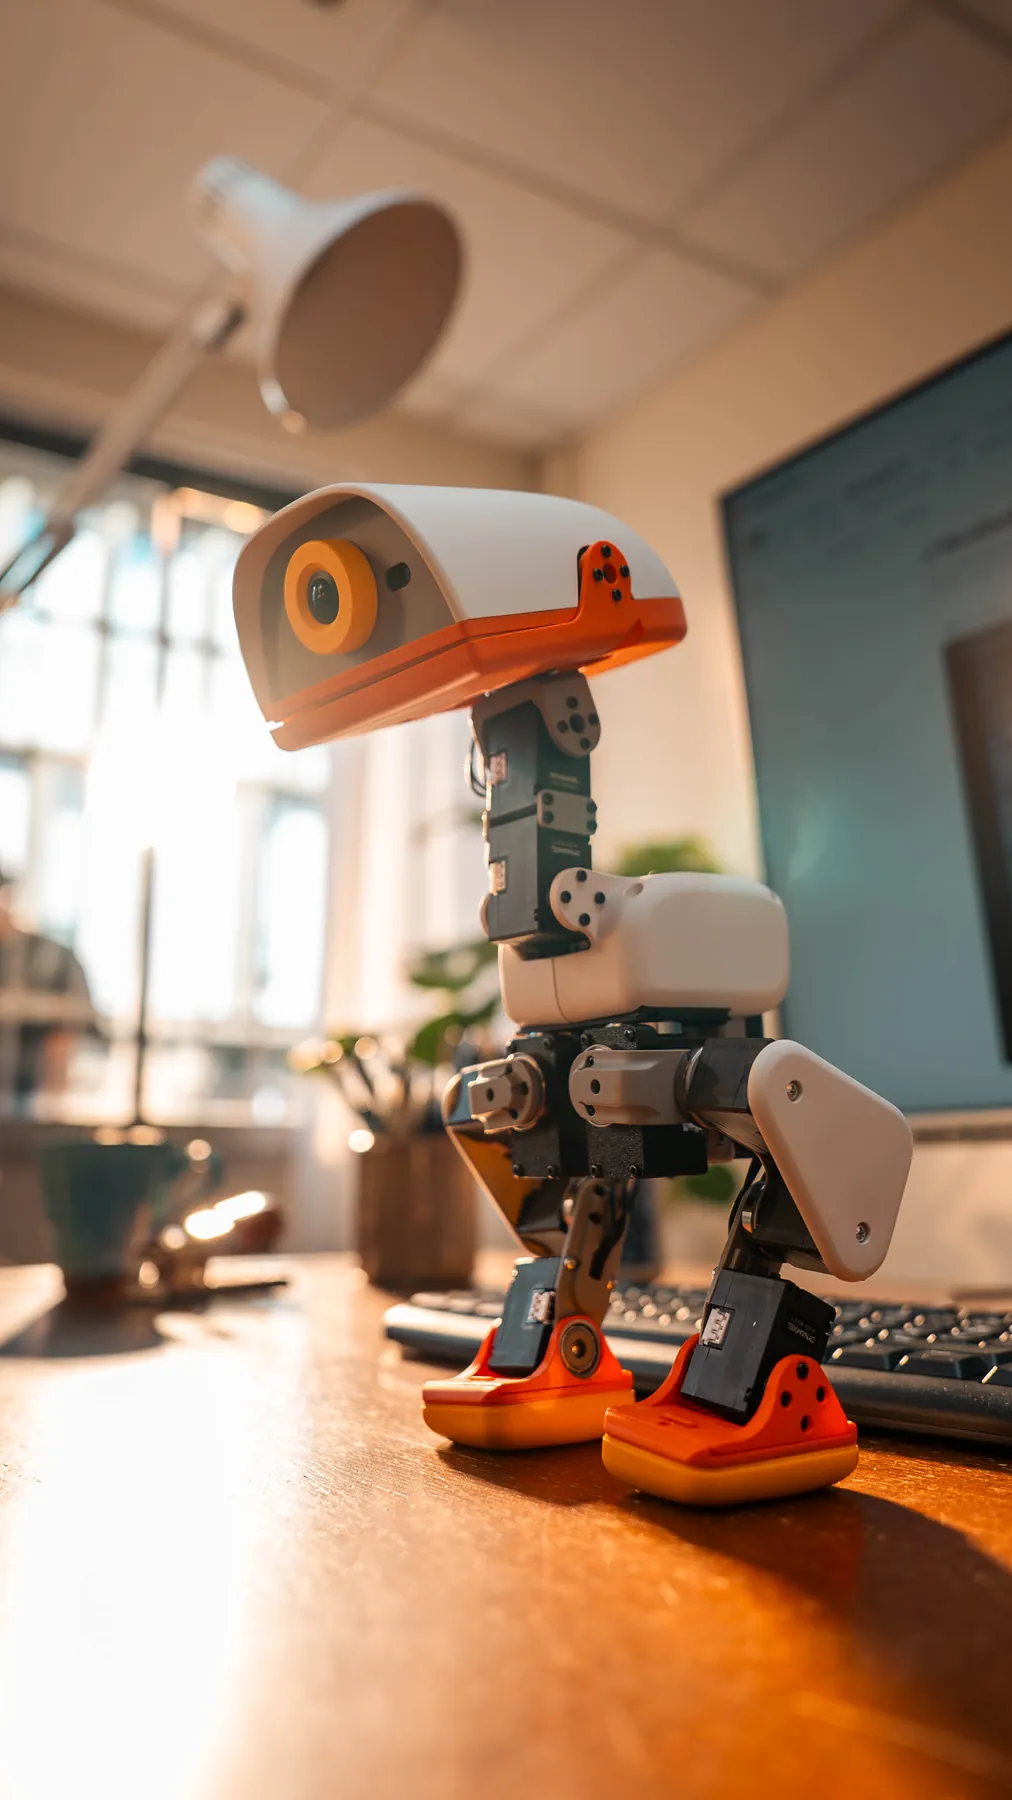 P-10MicroDuck RLComing soon
Select a hexagon to open or locate a project
about.md
Hey! I'm Luca Obwegs from Italy. I love robots, climbing and learning new things.
At Hilti's robotics lab, I design and build test setups for mechatronic and robotic platforms, automate tests and data logging in Python, analyse results to find failure modes, and feed findings back into design. I have contributed to five prototypes from simulation to hardware testing and supported customer acceptance tests for Stop Assist for power tools.
I work hands-on in the workshop with mechanical and electrical equipment, assembling mechatronic test setups and prototypes. I coordinate test and integration across mechanical, electronics and software engineers.
My projects combine test setups and measurement with embedded C++, Python data tools and ROS 2 interfaces, so I can take a mechatronic system from a first prototype to repeatable evidence of how it performs.
Feel free to get in touch or take a look at my work below.
languages
01 // career & education
Mechanical-engineering high school diploma, hands-on electrical assembly and soldering, plus summer internships at M2 Railtech working on mechatronic prototypes, microcontrollers and PCB design.
02 // skills
I design test rigs and fixtures, automate measurements, analyse data and turn failure findings into better mechatronic designs.
Building repeatable evidence from real mechatronic systems.
Robotics software, from pose calculations to command interfaces and hardware integration.
Model-based design and state estimation, followed by testing on physical hardware.
Real-time control loops on microcontrollers, close to the sensors and actuators.
Fusing noisy sensors into states a controller can rely on.
Connecting models, command interfaces and physical mechanisms.
Building the prototypes myself, so the software has something to run on.
03 // personal projects
Selected engineering work, ordered by robotics-control relevance rather than publication date. University coursework and personal interests are listed separately; confidential professional projects are not included.
A rotary double inverted pendulum with slip rings and CAN-connected sensors, built to swing up through all four equilibria with reinforcement learning and to explore MPC as an alternative.
View projectA 500 Hz STM32 balancing robot: LQR with pitch and wheel-encoder Kalman filters validated on hardware; PID/LQR controller comparison studied in simulation.
View projectBilateral force/position control with induced communication delay, time-domain passivity and adaptive inverse-dynamics control – MATLAB/Simulink simulation and hardware experiments at KAIST.
View projectMy TUM master's thesis: I redesigned and built a mobile, hydraulically actuated right-leg exoskeleton, implemented joint position control and tested tracking precision and hydraulic efficiency on the prototype.
View projectA two-axis tracking prototype and simulation with detailed stepper-servo modelling, sensor fusion and delayed-measurement compensation.
View projectA fully 3D-printed six-axis robot arm inspired by the ABB IRB 1100 – stepper drives, numerical inverse kinematics, a teach-in GUI and a separate ROS 2 command publisher.
View projectA custom STM32 quadrotor controller: IMU-to-PWM embedded control, plus a separate MATLAB study of PID, LQR, constrained MPC and aided navigation EKF.
View projectA 16 × 16 × 13 mm, 5.51 g flight instrument: custom four-layer PCB, STM32 firmware and a barometer/IMU estimator turn vertical movement into audible climb cues.
View projectA paragliding variometer built from scratch around an ESP8266, with GPS, barometer, accelerometer and Kalman-filter sensor fusion.
View projectA custom robot actuator designed to measure torque, position and velocity – the building block for a force-controlled 3-DOF robot.
View projectAn upcoming build of the open-source MicroDuck biped, focused on learning reinforcement learning, locomotion training and the path from simulation to real hardware.
View project04 // publications & IP
S. Groß, L. Obwegs, J. Li, T. Spiegeler Castañeda, A. Ganguly, C. Piazza, and S. Haddadin, Transforming Tactile Interfaces: Tri-Axis Force Sensor for Sensory Signal Processing, work-in-progress contribution accepted at IEEE World Haptics 2023, Delft.
Stop Assist for power tools – data-driven automated stopping controller for assisting operators in driving screws. Patent filed (2025P00312EP); 50% contribution. This patent resulted in an industrialization project and customer acceptance tests.
Additional Hilti patent application filed; details withheld pending clearance.
05 // university coursework
Selected hands-on projects completed as part of robotics and autonomous-systems courses.
A ROS-based differential-drive robot that mapped an unknown environment, found a visual goal, collected a magnetic red ball and delivered it autonomously.
A simulated autonomous drone that used its camera to map a Unity environment and navigate to a goal through a ROS perception, planning and control pipeline.
06 // personal interests
In 2023, Lucas and I opened Via Eureka: an eight-pitch route on Lagazuoi. Climbing is a personal interest, separate from my engineering work.
Explore Via Eureka Climbing log & personal goals